This protocol presents a reproducible deep learning workflow using multichannel cycling data and engineered features to predict lithium-ion battery state of health, remaining useful life, and energy-storage performance.
A subscription to JoVE is required to view this content. Sign in or start your free trial.
Method Article
A Reproducible Deep Learning Workflow for Predicting Lithium-Ion Battery Performance Using Multichannel Cycling Data
In This Article
Summary
Abstract
This protocol presents a reproducible deep-learning workflow for predicting lithium-ion battery performance using multichannel cycling data. To address limitations in existing data-driven models related to multisource information integration and feature representation, the method utilizes five publicly available battery datasets. The inputs include raw operational signals, including voltage, current, capacity, temperature, internal resistance, and coulombic and energy efficiency, together with engineered features such as incremental capacity, differential voltage, and energy throughput. The protocol details standardized preprocessing procedures for constructing battery-level temporal tensors across multiple observation windows. To improve reproducibility, the workflow evaluates candidate neural-network architectures, including deep neural networks, convolutional neural networks (CNNs), long short-term memory (LSTM) networks, CNN–LSTM, and transformer-based models, using fixed random seeds, repeated evaluation runs, and environment tracking. Representative results demonstrated that the CNN–LSTM architecture with integrated multichannel data and engineered features achieved favorable predictive performance among the evaluated models. The selected configuration achieved a mean absolute error of 0.024 and an R2 value of 0.955 for state-of-health estimation while maintaining high predictive performance for remaining useful life and dischargeable-energy estimation. Ablation and robustness analyses further demonstrated the contribution of multichannel feature integration and the stability of the reproducibility-focused workflow across repeated evaluations. This standardized methodology provides a reproducible framework for battery lifecycle management and predictive modeling under diverse operating conditions.
Introduction
Lithium-ion batteries are central to the global transition toward renewable energy because of their high energy density, extended cycle life, and low self-discharge rates across applications ranging from portable electronics to grid-scale energy storage systems. However, prolonged operation inevitably leads to gradual capacity degradation and increased internal resistance1. This performance decline not only reduces economic viability but also introduces severe safety hazards, including thermal runaway. As the deployment of large-scale energy storage systems continues to accelerate, battery lifecycle management has become increasingly complex2. Traditional threshold-based monitoring and manual inspection protocols are insufficient for dynamic operating environments3. Furthermore, reliance on a single parameter is inadequate for accurately predicting battery state of health (SOH) or remaining useful life (RUL) under fluctuating charge-discharge rates, ambient temperatures, and discharge voltage variations4. Although the current workflow was primarily validated using laboratory-controlled cycling datasets, the multichannel architecture and temporal modeling framework may support future adaptation to dynamic operating conditions encountered in electric-vehicle applications and variable environmental environments.
Battery degradation is a highly complex, nonlinear electrochemical process driven by solid electrolyte interphase growth, loss of active lithium, and structural deterioration of electrode materials. Historically, state estimation has relied on equivalent-circuit models or electrochemical-physical partial differential equations (PDEs)5. Although these physical models provide valuable mechanistic insights, they suffer from substantial computational overhead and parameter-identification challenges when processing multichannel coupled signals. Consequently, their real-time implementation in embedded battery-management systems (BMSs) is severely constrained by complex diffusion kinetics and environmental variability under high-rate discharge conditions6. In contrast, the proposed deep-learning (DL) workflow concentrates most computational demand within the offline training phase, while the trained model performs comparatively rapid inference during deployment. This framework may therefore support future implementation in resource-constrained BMSs and edge-computing environments.
Recently, data-driven DL approaches have emerged as powerful tools because of their exceptional nonlinear fitting capabilities. Nonetheless, existing DL methodologies exhibit two major limitations. First, many approaches rely primarily on single-capacity degradation curves or specific discharge-voltage thresholds while neglecting the inherent spatiotemporal correlations among multichannel cycling responses, such as voltage, current, and temperature. This limitation reduces model robustness under multicondition operating scenarios7. Previous studies have shown that neglecting thermal states during complex operations can accelerate the accumulation of predictive errors8,9. Second, a persistent reproducibility challenge exists in applied machine learning (ML). Variations in experimental conditions, insufficiently described preprocessing pipelines, and arbitrarily selected neural network hyperparameters frequently cause otherwise robust models to fail during cross-dataset validation10. To reduce the risk of information leakage during preprocessing and early-cycle forecasting, the proposed workflow derives normalization scaling factors and engineered-feature baselines exclusively from the training datasets prior to external validation and cross-dataset evaluation.
To address these critical gaps, the overall goal of this protocol is to present an automated, highly reproducible DL workflow for predicting lithium-ion battery energy-storage performance using multichannel cycling data. The rationale behind this method is to explicitly capture the complex long-term dependencies associated with battery degradation by integrating cross-modal time-series data within a high-dimensional neural network architecture. A key advantage of this protocol over existing physics-based and DL approaches is its holistic standardization, which establishes a complete pipeline spanning raw-signal preprocessing, feature engineering, model training, and uncertainty evaluation. Although hybrid neural-network architectures have been previously investigated, the present workflow emphasizes standardized multichannel integration by aligning electrochemical cycling variables with engineered degradation features within a reproducibility-focused training framework. Unlike many previously reported workflows, this protocol incorporates standardized parameter configurations, fixed random seeds, repeated evaluation runs, and comprehensive environment tracking to improve reproducibility across heterogeneous battery datasets and laboratory settings. In addition, the workflow systematically compares multiple neural-network architectures to evaluate predictive stability and performance across different input configurations. Within the evaluated datasets and experimental settings, the convolutional neural network–long short-term memory (CNN–LSTM) architecture demonstrated favorable predictive performance relative to the evaluated standalone CNN and transformer-based models by combining local feature extraction with long-range temporal sequence modeling while maintaining moderate computational complexity. This protocol is well suited for researchers and engineers seeking to develop reproducible and environment-adaptive predictive models for battery lifecycle management.
Access restricted. Please log in or start a trial to view this content.
Protocol
Institutional ethics approval was not required for this study because the research exclusively utilized publicly available lithium-ion battery cycling datasets and did not involve human participants, animal subjects, or biological samples.
1. Data Acquisition and Organization
- Acquire multichannel cycling datasets
- Download lithium-ion battery cycling datasets from publicly available battery repositories containing charge-discharge cycling records. Acquire the CALCE, SANYO, PANASONIC, KOKAM, and GOTION datasets directly from their respective institutional open-access repositories or digital object identifier links to maintain dataset-version consistency.
- Select battery samples containing complete cycle numbers, capacity measurements, and at least one continuous charge-discharge curve. Verify continuity by confirming that no interruption exceeding two hours occurs within a single cycle and that both constant-current and constant-voltage phases are fully recorded.
- Filter raw cycling records
- Filter the raw cycling records to retain samples containing temperature, internal resistance, coulombic efficiency, and energy-efficiency measurements. Exclude battery cells lacking these mandatory state channels from the analysis workflow because subsequent multichannel feature fusion requires a complete set of physical input variables.
- Remove cycles containing incomplete records, inconsistent timestamps, undefined testing procedures, or unclear charge-discharge termination conditions. Define anomalous cycles as those exhibiting sudden capacity drops exceeding 5% between adjacent cycles, voltage measurements outside the chemistry-specific operating range, or nonmonotonic timestamp intervals.
- Construct a temporal battery database
- Organize the retained cycling records chronologically to construct a battery-level time-series database.
- Store the processed datasets using Hierarchical Data Format version 5 (HDF5). Maintain a standardized directory structure organized by dataset source, chemical system, and individual battery-cell identifier.
- Assign unique identifiers to individual battery cells before dataset partitioning. Implement grouping based on the battery-cell identifier during train-test splitting to ensure that all sequential cycles from a single physical battery remain exclusively within one dataset subset.
NOTE: Preserve the original raw datasets separately before preprocessing, normalization, resampling, or feature engineering.
- Define observation windows
- Construct multichannel observation windows using the first 50 cycles, the first 100 cycles, and the first 20% of the total battery lifecycle. Calculate the 20% lifecycle threshold by multiplying the total cycle life before end-of-life capacity degradation by 0.2.
- Align voltage, current, capacity, temperature, internal resistance, and efficiency measurements within each observation window before tensor construction.
- Format the final input structure as a three-dimensional tensor consisting of the observation-window length, 128 standardized intra-cycle sampling points, and the ordered multichannel feature set.
2. Data Preprocessing and Feature Engineering
- Preprocess raw cycling data
- Perform uniform preprocessing on the raw cycling datasets to standardize data quality across all battery sources. Execute all preprocessing, synchronization, and standardization procedures using Python 3.10 with the Pandas library for time-series manipulation and SciPy for numerical interpolation.
- Remove outliers, detect missing values, calibrate timestamps, identify charge-discharge phases, and normalize sampling frequencies before downstream analysis. Apply a modified Z-score thresholding method with a rejection criterion greater than 3.0 for anomaly detection.
- Detect missing values automatically using NaN flag identification across all numerical arrays. Differentiate charging and discharging phases according to current polarity by assigning positive current values to charging cycles and negative current values to discharging cycles.
- Reconstruct missing signal segments using piecewise cubic Hermite interpolating polynomials to preserve electrochemical temporal dynamics during phase-transition alignment.
- Resample cycling curves
- Resample cycling curves when variations in sampling density or signal drift are detected across datasets. Trigger automated resampling whenever the interval between consecutive measurements deviates by more than 10% relative to the median sampling frequency of the corresponding cycling phase.
- Standardize the number of sampling points within each cycle to reduce platform-specific recording variation. Map all temporal sequences onto a fixed spatial grid using one-dimensional linear interpolation.
- Compress or expand each charge-discharge profile into exactly 128 equidistant sampling points before tensor construction.
- Normalize continuous variables
- Normalize all continuous variables before model training to stabilize network convergence and reduce scale-related bias. Apply Min-Max scaling to transform all continuous variables into a numerical range between 0 and 1.
- Compute all normalization parameters exclusively from the training dataset. Apply the frozen scaling parameters to the validation and testing datasets to reduce the risk of forward temporal data leakage during early-cycle prediction.
- Construct multichannel input tensors
- Divide the continuous cycling records for each battery into fixed-length temporal segments. Structure the temporal segments according to the predefined observation windows corresponding to the first 50 cycles, the first 100 cycles, or the first 20% of the battery lifecycle.
- Align voltage, current, capacity, temperature, internal-resistance, and efficiency measurements within each temporal segment before tensor construction.
- Concatenate the aligned feature matrices into a three-dimensional tensor formatted as (N × 128 × C), where N represents the observation-window length, 128 denotes the standardized intra-cycle sampling points, and C represents the total number of physical and engineered feature channels.
- Extract engineered features
- Extract engineered electrochemical features from the raw cycling signals to improve degradation-pattern identification. Calculate incremental-capacity and differential-voltage features by computing dQ/dV and dV/dQ across the standardized sampling grid.
- Apply Savitzky–Golay filtering to generate smoothed incremental-capacity and differential-voltage curves.
- Extract degradation indicators including peak-voltage shifts, phase-transition voltage differences, and cycle-to-cycle energy-throughput variations from the filtered electrochemical features.
3. DL Model Construction and Training
- Construct candidate prediction models
- Construct a standardized training and evaluation framework for all prediction models shown in Figure 1A. Implement the DL workflow using PyTorch version 2.0 or higher.
- Execute the training workflow using modular Python scripts for data loading, model initialization, optimization, and evaluation.
- Prepare traditional ML baseline models including linear regression, random forest, and gradient-boosted decision-tree models. Configure the random-forest model with 100 trees and a maximum depth of 10.
- Configure the gradient-boosted decision-tree framework using a learning rate of 0.1 and a maximum tree depth of 5 through the Scikit-learn library.
- Prepare DL candidate architectures including multilayer perceptron, one-dimensional CNN, LSTM network, CNN–LSTM, and transformer-based models.
- Standardize the core hyperparameters across all DL architectures by applying the AdamW optimizer, Gaussian error linear unit activation functions, a hidden dimension of 128, and a dropout rate of 0.2.
- Configure the CNN–LSTM architecture
- Configure the CNN–LSTM architecture to fuse multichannel cycling information from the input tensors (Figure 1B). Construct the hybrid architecture by cascading the convolutional feature extractor into two stacked recurrent layers containing 128 hidden units each.
- Terminate the architecture using three parallel fully connected regression heads for simultaneous prediction of SOH, RUL, and dischargeable energy.
- Process the multichannel input tensors through three consecutive one-dimensional convolutional layers with kernel sizes of 3, 5, and 7 to extract multiscale localized features.
- Apply batch normalization after each convolutional layer to improve gradient stability during optimization.
- Reshape the convolutional feature maps into continuous temporal sequences before sequence modeling.
- Feed the encoded temporal sequences into stacked recurrent layers to capture long-range degradation dependencies across the predefined observation windows.
- Partition datasets for model training
- Partition the processed battery-cell datasets into training, validation, and testing subsets using a 70:15:15 ratio. Execute the dataset split using a fixed random seed value of 42.
- Apply stratified sampling based on battery chemistry to maintain balanced degradation distributions across all dataset subsets.
- Perform dataset partitioning strictly at the battery-cell level rather than randomizing individual cycles to preserve sequential degradation trajectories.
- Keep each battery cell as an indivisible unit during partitioning to prevent information leakage between datasets.
- Verify dataset isolation programmatically by computing the intersection of battery-cell identifiers across the training, validation, and testing subsets and confirming that no overlap exists.
- Compile an external test dataset using the complete GOTION lithium iron phosphate (LFP) dataset for out-of-distribution evaluation and cross-dataset generalization assessment.
- Make the source code, environment-configuration files, and processed dataset partitions publicly available through a dedicated GitHub repository to support methodological transparency and reproducibility.
- Initialize model training
- Set the regression loss function to mean squared error before training. Compute the global training objective by aggregating the loss values from each prediction target using equal weighting.
- Set the initial learning rate to 1 × 10⁻³ and select a batch size of 32 or 64 according to dataset size.
- Use a batch size of 64 for datasets containing more than 5,000 cycles to improve hardware utilization. Use a batch size of 32 for smaller datasets to improve optimization stability.
NOTE: Select these hyperparameters through preliminary grid-search evaluation to balance convergence speed and gradient stability across different observation windows.
- Apply training controls
- Apply a dynamic learning-rate scheduler based on validation-loss changes. Reduce the learning rate by a factor of 0.5 if the validation loss fails to improve over 5 consecutive epochs.
- Maintain a minimum learning-rate threshold of 1 × 10⁻⁵ during optimization.
- Stop model training after a maximum of 100 epochs to reduce overfitting.
- Apply early stopping if the validation loss does not decrease over 15 consecutive epochs. Restore the model weights corresponding to the best-performing validation iteration.
- Maintain reproducibility records
- Set a fixed random seed value of 42 before model initialization and training.
- Apply the fixed random seed consistently across the Python random module, NumPy, and the PyTorch backend while disabling nondeterministic CUDA operations.
- Record the software environment, dependency versions, parameter settings, data partitions, and training outputs for each experimental run.
- Execute all DL workflows using Ubuntu 22.04 with CUDA 11.8 acceleration on a workstation equipped with an NVIDIA RTX 3090 graphics processing unit or equivalent hardware.
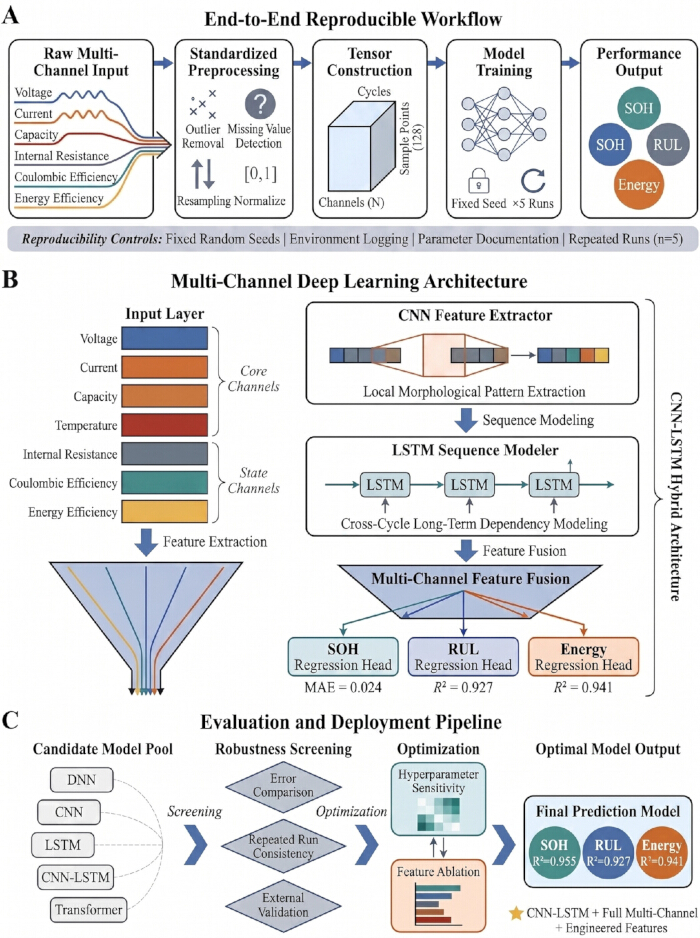
Figure 1. Reproducible deep-learning (DL) workflow for multichannel lithium-ion battery performance prediction. (A) End-to-end reproducible workflow illustrating multichannel data acquisition, standardized preprocessing, tensor construction, model training, and prediction of battery performance indicators. Reproducibility controls include fixed random seeds, repeated training runs, parameter tracking, and environment logging. (B) CNN–LSTM hybrid architecture used for multichannel feature extraction, temporal sequence modeling, feature fusion, and prediction of state of health (SOH), remaining useful life (RUL), and dischargeable energy. (C) Evaluation and deployment pipeline showing candidate model screening, robustness evaluation, hyperparameter optimization, and final model selection. Please click here to view a larger version of this figure.
4. Model Evaluation and Target Prediction
- Generate model predictions
- Process the target test-battery datasets through each trained model. Load the preprocessed test datasets as serialized PyTorch tensors before inference.
- Execute the forward inference pass using a gradient-disabling context manager to prevent unintended parameter updates during evaluation.
- Generate concurrent predictions for each performance indicator using the trained regression heads.
- Extract simultaneous outputs from the three parallel regression heads configured for SOH, RUL, and dischargeable-energy prediction.
- Calculate prediction targets
- Calculate SOH by comparing the present available capacity with the initial battery capacity.
- Define the initial battery capacity as the maximum discharge capacity recorded during the first three stabilization cycles.
- Compute SOH as the ratio between the present-cycle capacity and the established initial-capacity baseline.
- Estimate RUL by identifying the operational threshold at which stable battery capacity ceases.
- Define end of life as the cycle number at which battery capacity irreversibly decreases below 80% of the nominal rated capacity.
- Calculate RUL as the remaining cycle count from the current observation point to the defined end-of-life threshold.
- Forecast dischargeable energy from the recorded discharge conditions.
- Compute the ground-truth dischargeable energy by numerically integrating the product of discharge voltage and discharge current across the discharge interval using the trapezoidal integration method.
- Evaluate predictive performance
- Calculate mean absolute error (MAE), root mean square error (RMSE), mean absolute percentage error (MAPE), and coefficient of determination (R2) for each prediction target.
- Compute all evaluation metrics using the Scikit-learn metrics module with standardized statistical formulations.
- Apply identical metric calculations across all models, datasets, and input configurations to maintain evaluation consistency.
- Aggregate all performance metrics across the pooled battery samples within the independent testing dataset to evaluate overall model generalization.
- Report stratified performance
- Calculate the mean and standard deviation for each evaluation metric across repeated experimental runs.
- Derive the reported statistical measures from five independent model initializations.
- Report 95% confidence intervals together with the mean performance metrics to quantify predictive uncertainty.
- Compare model performance across different observation-window lengths and input-channel configurations.
- Stratify the comparative analysis using observation windows corresponding to 50 cycles, 100 cycles, and 200 cycles.
- Evaluate predictive performance across multiple input configurations ranging from capacity-only inputs to full multichannel tensor integration. Refer to Figure 1C for the evaluation, robustness-screening, and deployment-selection workflow.
5. Reproducibility, Robustness, and Sensitivity Analysis
- Verify reproducibility and robustness
- Maintain identical data partitions, preprocessing workflows, and experimental procedures across all reproducibility evaluations shown in Figure 2A.
- Compute the coefficient of variation for the primary evaluation metrics across repeated trials to assess reproducibility consistency.
- Repeat all evaluation procedures using the same standardized training and testing workflow.
- Initialize each repeated evaluation using randomized network weights while preserving the same deterministic data-loading and shuffling procedures.
- Perform repeated training experiments
- Train the prediction models repeatedly under identical experimental conditions using predefined fixed random-seed values to ensure reproducible weight initialization.
- Perform five independent training runs using identical dataset partitions to reduce data-driven variability.
- Calculate the final performance metrics by averaging the evaluation metrics obtained from the five repeated training runs.
- Aggregate the final robustness metrics using the averaged evaluation scores rather than combining raw prediction tensors.
- Evaluate hyperparameter sensitivity
- Modify the learning rate, batch size, hidden-layer dimension, and dropout ratio individually during sensitivity analysis.
- Evaluate learning rates ranging from 1 × 10⁻⁴ to 1 × 10⁻², batch sizes ranging from 32 to 128, hidden dimensions ranging from 32 to 256, and dropout ratios ranging from 0.1 to 0.5.
- Record the corresponding changes in predictive accuracy after each hyperparameter adjustment.
- Quantify predictive-performance variation using RMSE and R2.
- Perform feature-ablation analysis
- Remove selected input channels, including temperature, internal resistance, and engineered-feature vectors, from the multichannel input stream.
- Perform feature ablation using a leave-one-out strategy by removing one feature group at a time while preserving the remaining multichannel input structure.
- Compare the resulting predictive performance after each feature-removal experiment to evaluate the contribution of individual feature groups to model stability and accuracy.
- Quantify the relative contribution of each feature group by calculating the percentage increase in mean absolute error relative to the fully integrated multichannel baseline model. Refer to Figure 2B for the robustness-evaluation and sensitivity-analysis workflow
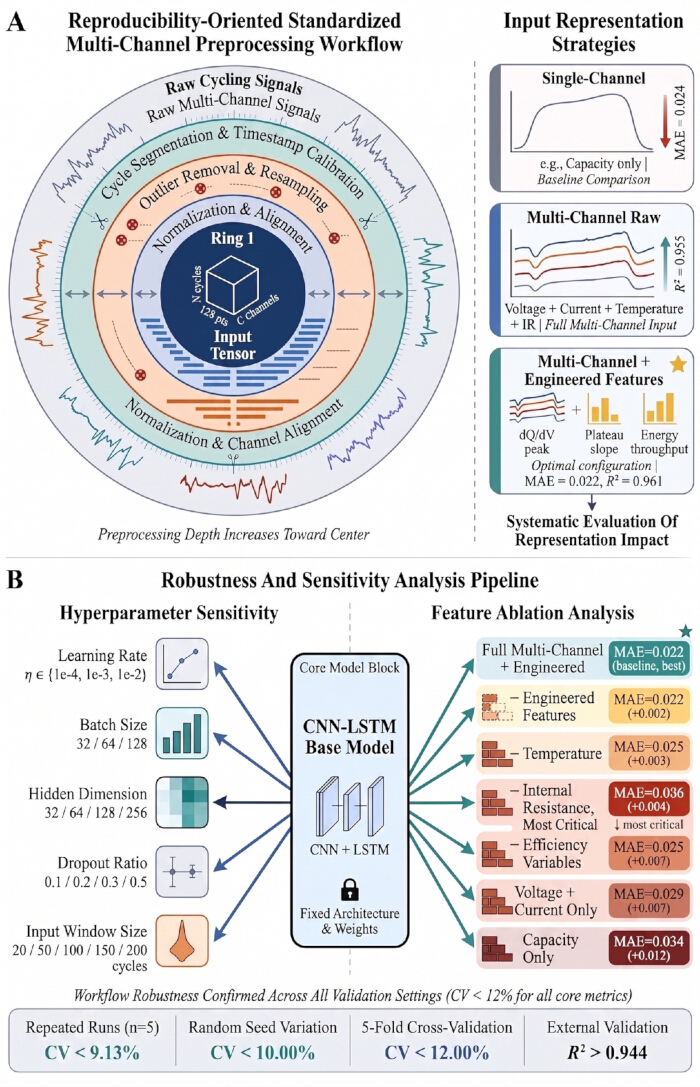
Figure 2. Standardized preprocessing, robustness evaluation, and sensitivity-analysis workflow. (A) Standardized multichannel preprocessing workflow illustrating raw cycling-signal processing, timestamp calibration, outlier removal, resampling, normalization, channel alignment, and tensor construction. Input-representation strategies compare single-channel inputs, multichannel raw inputs, and multichannel inputs combined with engineered features. (B) Robustness and sensitivity-analysis pipeline showing systematic hyperparameter perturbation, repeated-run evaluation, feature-ablation analysis, cross-validation, and external validation of the CNN–LSTM workflow. Please click here to view a larger version of this figure.
Access restricted. Please log in or start a trial to view this content.
Results
Multichannel Cycling Signals and Data Distribution
Representative multichannel cycling signals and performance distributions were analyzed to characterize the cycling-response behavior of lithium-ion batteries. The study utilized five lithium-ion battery datasets representing multiple chemical systems, including lithium cobalt oxide (LCO), nickel cobalt aluminum oxide (NCA), nickel manganese cobalt oxide (NMC), and LFP (Table 1). Core cycling variables, includ...
Access restricted. Please log in or start a trial to view this content.
Discussion
The reproducible DL workflow described in this protocol demonstrated accurate prediction of lithium-ion battery performance using multichannel cycling data. The workflow achieved a test MAE of 0.024 and a R2 value of 0.955 for SOH estimation under the evaluated experimental conditions, supporting its potential utility for battery lifecycle management and energy-storage monitoring applications11,12,13.
Access restricted. Please log in or start a trial to view this content.
Disclosures
The authors declare no competing financial interests or conflicts of interest.
Acknowledgements
The authors acknowledge the institutional support provided by the Department of Physics at Southern University of Science and Technology and Homerton College, University of Cambridge, which provided the academic environment and computational resources necessary for this research. The authors also thank the research institutions and contributors who made the open-access lithium-ion battery datasets, including CALCE, SANYO, PANASONIC, KOKAM, and GOTION, publicly available, thereby enabling this comprehensive multichannel analysis.
Access restricted. Please log in or start a trial to view this content.
Materials
| Name | Company | Catalog Number | Comments |
|---|---|---|---|
| CALCE battery dataset | Center for Advanced Life Cycle Engineering (CALCE), University of Maryland | https://calce.umd.edu/battery-data | Source of multichannel lithium-ion battery cycling data for model training and validation |
| CUDA Toolkit | NVIDIA | Version 11.8 | GPU acceleration for DL model training |
| GOTION IFP20100140A dataset | Mendeley Data | https://doi.org/10.17632/vpw4t7ytbx.2 | External validation and multichannel battery degradation analysis |
| KOKAM SLPB533459H4 dataset | Mendeley Data | https://doi.org/10.17632/7w4y4fzzbb.1 | Multichannel battery degradation modeling and validation |
| Matplotlib | Matplotlib Development Team | Version 3.7.1 | Visualization of model performance, sensitivity analysis, and reproducibility results |
| NumPy | NumPy Developers | Version 1.24.3 | Numerical computation and tensor construction |
| PANASONIC NCR18650BD dataset | Mendeley Data | https://doi.org/10.17632/wykht8y7tg.1 | Source of multichannel cycling data and engineered-feature extraction |
| Pandas | Pandas Developers | Version 2.0.3 | Data organization, preprocessing, and tabular-data management |
| PyTorch | PyTorch Foundation | Version 2.0.1 | Construction and training of deep-learning architectures, including the CNN–LSTM model |
| Python | Python Software Foundation | Version 3.10.12 | Data preprocessing, feature engineering, model training, and evaluation |
| SANYO UR18650E dataset | NASA Prognostics Data Repository | https://ti.arc.nasa.gov/tech/dash/groups/pcoe/prognostic-data-repository/ | Source of multichannel cycling data for reproducibility evaluation and model validation |
| Scikit-learn | Scikit-learn Developers | Version 1.2.2 | Baseline-model implementation, dataset partitioning, and performance-metric calculation |
References
- Lu J, Xiong R, Tian J. Deep learning to estimate lithium-ion battery state of health without additional degradation experiments. Nat Commun. 2023;14:2760.
- Zhang H, Li Y, Zheng S. Battery lifetime prediction across diverse ageing conditions with inter-cell deep learning. Nat Mach Intell. 2025;7:270–7.
- Zhang Y, et al. State-of-health estimation for lithium-ion batteries via incremental energy analysis and hybrid deep learning model. Batteries. 2025;11(6):217.
- Liu C, et al. Deep learning for state of health estimation of lithium-ion batteries in electric vehicles: A systematic review. Energies. 2025;18(6):1463.
- Chen C, Wei J, Li Z. Remaining useful life prediction for lithium-ion batteries based on a hybrid deep learning model. Processes. 2023;11(8):2333.
- Chen B, et al. Lithium-ion battery state of health estimation based on feature reconstruction and Transformer-GRU parallel architecture. Energies. 2025;18(5):1236.
- Zhao W, Ding W, Zhang S, Zhang Z. Enhancing lithium-ion battery lifespan early prediction using a multi-branch vision transformer model. Energy. 2024;302:131816.
- Hu J, et al. Early prediction of lithium-ion battery degradation with a generative pre-trained transformer. Nat Commun. 2026;17:126.
- Li Y, et al. Accurate and adaptive state of health estimation for lithium-ion battery based on patch learning framework. Measurement. 2025;250:117083.
- Geng M, et al. Interpretable deep learning with uncertainty quantification for lithium-ion battery SOH estimation. Energy. 2025;335:138027.
- Li Y, et al. State-of-health prediction of lithium-ion batteries using feature fusion and a hybrid neural network model. Energy. 2025;319:135163.
- Zhou J, et al. Deep learning estimation of state of health for lithium-ion batteries using multi-level fusion features of discharge curves. J Power Sources. 2025;653:237781.
- Wang Y, et al. A comprehensive review of machine learning-based state of health estimation for lithium-ion batteries: Data, features, algorithms, and future challenges. Renew Sustain Energy Rev. 2025;224:116125.
- Severson KA, et al. Data-driven prediction of battery cycle life before capacity degradation. Nat Energy. 2019;4(5):383–91.
- Wu R, et al. Confidence-aware quantile Transformer for reliable degradation prediction of battery energy storage systems. Reliab Eng Syst Saf. 2025;260:111019.
- Yang H, et al. Privacy-preserving collaborative battery fault warning for massive electric vehicles by heterogeneous data from charging stations. Nat Commun. 2026;17:974.
- Liu Y, et al. A hybrid deep learning approach for remaining useful life prediction of lithium-ion batteries based on discharging fragments. Appl Energy. 2024;358:122555.
- Bockrath S, Lorentz V, Pruckner M. State of health estimation of lithium-ion batteries with a temporal convolutional neural network using partial load profiles. Appl Energy. 2023;329:120307.
- Zhang Z, et al. Multi-cycle charging information guided state of health estimation for lithium-ion batteries based on pre-trained large language model. Energy. 2024;313:133993.
- Li Z, Zhang X, Gao W. State of health estimation of lithium-ion battery during fast charging process based on BiLSTM-Transformer. Energy. 2024;311:133418.
- Bao X, et al. Hybrid deep neural network with dimension attention for state-of-health estimation of lithium-ion batteries. Energy. 2023;278:127734.
- He N, et al. Early prediction of battery lifetime based on graphical features and convolutional neural networks. Appl Energy. 2024;353:122048.
- Rieger LH, et al. Uncertainty-aware and explainable machine learning for early prediction of battery degradation trajectory. Digit Discov. 2023;2(1):112–22.
- Li H, et al. A cross-material lithium-ion battery state of health estimation method based on three-stage domain adaptation. Energy. 2025;139376.
- Han T, et al. Source-free dynamic weighted federated transfer learning for state-of-health estimation of lithium-ion batteries with data privacy. IEEE Trans Power Electron. 2024;39(11):15085–100.
- Rhyu J, et al. Systematic feature design for cycle life prediction of lithium-ion batteries during formation. Joule. 2025;9(5):101884.
Access restricted. Please log in or start a trial to view this content.