WheelCon is a novel, free and open-source platform to design video games that noninvasively simulates mountain biking down a steep, twisting, bumpy trail. It contains components presenting in human sensorimotor control (delay, quantization, noise, disturbance, and multiple feedback loops) and allows researchers to study the layered architecture in sensorimotor control.
A subscription to JoVE is required to view this content. Sign in or start your free trial.
Method Article
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
In This Article
Summary
Abstract
Feedback control theory has been extensively implemented to theoretically model human sensorimotor control. However, experimental platforms capable of manipulating important components of multiple feedback loops lack development. This paper describes WheelCon, an open-source platform aimed at resolving such insufficiencies. Using only a computer, a standard display, and inexpensive gaming steering wheel equipped with a force feedback motor, WheelCon safely simulates the canonical sensorimotor task of riding a mountain bike down a steep, twisting, bumpy trail. The platform provides flexibility, as will be demonstrated in the demos provided, so that researchers may manipulate the disturbances, delay, and quantization (data rate) in the layered feedback loops, including a high-level advanced plan layer and a low-level delayed reflex layer. In this paper, we illustrate WheelCon's graphical user interface (GUI), the input and output of existing demos, and how to design new games. In addition, we present the basic feedback model and the experimental results from the demo games, which align well with the model's prediction. The WheelCon platform can be downloaded at https://github.com/Doyle-Lab/WheelCon. In short, the platform is featured to be cheap, simple to use, and flexible to program for effective sensorimotor neuroscience research and control engineering education.
Introduction
The human sensorimotor control system is extremely robust1, although the sensing is distributed, variable, sparse, quantized, noisy and delayed2,3,4; the computing in the central nervous system is slow5,6,7; and the muscle actuation fatigues and saturates8. Many computational theoretical models have been proposed to explain the complicated human sensorimotor control process4,9
Access restricted. Please log in or start a trial to view this content.
Protocol
The development and application of the protocol were approved by the California Institute of Technology Institutional Review Board (IRB) and the Southern University of Science and Technology IRB. The subject provided informed consent prior to any procedures being performed.
1. System preparation and setup
- The recommended basic hardware is a 2 GHz dual-core processor and 4 GB of system memory.
- Build the gaming platform under the Unity platform, while using C# programing language. The Logitech gaming wheel driver and Logitech Steering Wheel SDK are needed for gaming platform development.
- The gaming platfor....
Access restricted. Please log in or start a trial to view this content.
Results
Modelling Feedback Control
We show a simplified feedback control model shown in Figure 1. The system dynamics is given by:
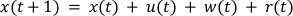
where x(t) is the error at time t,.......
Access restricted. Please log in or start a trial to view this content.
Discussion
In this paper, we have presented a free, open-source gaming platform, WheelCon, for studying the effects of delay, quantization, disturbance, and layered feedback loops in human sensorimotor control. We have shown the hardware, the software, and the GUI. The settings of a single sensorimotor control loop with delay and quantization have been implemented, which allows us to measure the effects of delay, quantization, and disturbance in sensorimotor control. The experimental results are well in line with the prediction fro.......
Access restricted. Please log in or start a trial to view this content.
Disclosures
The authors disclose that they have no conflicts of interest.
Acknowledgements
We thank Mr. Zhengyang Wang for reshaping the scripts, shooting and editing the video, and Mr. Ziyuan Ye for editing the video. This study got support from CIT Endowment & National Science Foundation (to JCD), Boswell fellowship (to QL) and High-level University Fund (No. G02386301, G02386401), Guangdong Natural Science Foundation Joint Fund (No. 2019A1515111038).
....Access restricted. Please log in or start a trial to view this content.
Materials
| Name | Company | Catalog Number | Comments |
|---|---|---|---|
| Gaming Wheel | Logitech | ||
| Windows 10 OS | Microsoft |
References
- Franklin, D. W., Wolpert, D. M. Computational Mechanisms of Sensorimotor Control. Neuron. 72 (3), 425-442 (2011).
- Bays, P. M., Wolpert, D. M. Computational principles of sensorimotor control that minimize uncertainty and variability. The Journal of Physiology....
Access restricted. Please log in or start a trial to view this content.
Reprints and Permissions
