This protocol presents the configuration of a compression test device capable of precisely measuring the mechanical properties of microstructures in the small-strain region, along with a systematic method for compression testing using this device. The proposed device can be used to analyze various microstructures and the mechanical behavior of polymer-based materials.
A subscription to JoVE is required to view this content. Sign in or start your free trial.
Method Article
Measurement of Compressive Stress-Strain Response at Small-Strains
* These authors contributed equally
In This Article
Summary
Abstract
This study developed a measurement method capable of precisely evaluating the mechanical behavior of materials and microdevices in the small-strain region. The system integrates a motor-controlled z-stage, a microcontroller board, an operational amplifier circuit, and a force sensor, enabling synchronized force-displacement acquisition through custom control and serial communication. Calibration of the amplifier's variable resistor was performed to optimize the correlation between applied force and sensor output, yielding a relative error within ±2.0% when compared with a commercial universal testing machine. Vertical displacement accuracy was validated using a laser displacement meter at a target motion speed of 1 µm/s, showing a relative error of +0.1%. Accordingly, the platform provides a displacement resolution of 1 µm and a force resolution of 0.01 N. Compression tests were conducted on a polydimethylsiloxane (PDMS) sample fabricated at one-third of the standard ASTM D575-91 dimensions. Stress-strain responses measured by the proposed system and by the universal testing machine exhibited close agreement, and the compressive modulus estimated in the small-strain region showed a +5.3% deviation from previously reported values. These results confirm the reliability and repeatability of measurements in the small-strain region, supporting modulus estimation based on the initial linear slope under controlled compression. The developed platform is compact, straightforward to assemble, and cost-effective while maintaining high precision and operational stability. Its validated performance and reproducible calibration procedure make it suitable for laboratories requiring accurate characterization at low forces and small displacements. Potential application areas include polymer-based microelectromechanical systems (MEMS), soft robotics components, and microneedles, where precise, low-load compression testing and verifiable displacement control are essential for material evaluation and device design.
Introduction
Understanding of the mechanical behavior of microelectromechanical systems (MEMS) devices is crucial for device design, performance, and reliability1,2. Conventional universal testing machines have been widely used to evaluate mechanical properties; however, they are expensive and require substantial space, manpower, and resources for installation, maintenance, and operation3. Moreover, because they were primarily designed for high force and large displacement ranges in the mechanical testing of high-strength materials, there are significant discrepancies between their measurement ranges and those required for evaluating the mechanical properties of microstructures in the small-strain region4. Therefore, research is needed on a new low-cost compression testing apparatus and experimental method applicable at the laboratory scale with high repeatability that can yield reliable measurements in the small-strain/small-force region5.
Several mechanical testing devices that can be utilized at the laboratory scale have been developed to characterize the mechanical properties of small-scale MEMS devices6,7,8. However, most of these devices were developed for testing high-strength materials or for specialized environments, and therefore they have limitations in reliably measuring the mechanical properties of MEMS structures in the small-strain/small-force region9,10.
To overcome these limitations, we propose a small-displacement compression testing system and method that can be utilized in even small-scale laboratories. The proposed method enables the quantitative evaluation of a material's mechanical behavior by simultaneously measuring small displacements and forces during the compression process. The system operates within a 4.4 N force range and a controlled displacement speed of 1 µm/s, ensuring precise and stable measurements. The system is a compact, low-cost compression testing setup designed to evaluate the mechanical properties of microstructures in the small-strain region.
This system integrates a z-stage with a force sensor and microcontroller board-based signal acquisition, enabling simultaneous measurement of force and displacement with high precision. System validation was performed through feedback resistor (RF) calibration-the key factor in determining the gain of the inverting amplifier circuit-and verification of vertical displacement using a laser displacement meter, confirming that the displacement and force measurement resolutions were 1 µm and 0.01 N, respectively. Scaled-down samples11,12, with one-third of the standard size (American Society for Testing and Materials (ASTM) D575-91, Standard Test Methods for Rubber Properties in Compression)13, were fabricated, and a compression test method was derived to evaluate the mechanical properties of microstructures reliably in the small-displacement/low-force region14,15.
The stress-strain curves of the scaled samples were measured with both a commercial universal testing machine (MTS) and the developed measurement system (MS), and the results were compared. From the slope of the initial linear region, the compressive modulus was determined to be 1.39 MPa, which showed a +5.3% deviation from values previously reported in the literature16. This measurement approach, which combines displacement control and force measurement17,18, provides a reproducible measurement framework suitable for MEMS and bio-MEMS applications. This approach not only provides a reliable framework for understanding the mechanical behavior of microstructures but also offers a practical method for evaluating materials in various fields, including biomedical devices19 and soft robotics20.
Access restricted. Please log in or start a trial to view this content.
Protocol
The consumables, equipment, and software used are listed in the Table of Materials.
1. Measurement system setup
NOTE: Figure 1 shows the MS used for compression testing. The z-stage consists of a linear actuator controlled by a motor controller, a moving part that provides the actual motion along the z-axis, and a supporting fixed part. The system also includes a microcontroller board, an operational amplifier circuit, a force sensor attached to a block, and a laptop.
- Drive the moving part along the z-axis at the set speed using the motor controller to apply a compressive load to the sample.
- Measure the load using a force sensor mounted on top of a rigid metal block. The collected signal passes through an inverting amplifier circuit, is converted to a digital signal by the microcontroller board, and then transmitted to the microcontroller board software.
- Set up a laser displacement meter as shown in Figure 2 to verify the vertical displacement of the z-stage. After sending an input signal from the motor controller, allow the z-stage moving part to move vertically; the real-time displacement data of the embedded linear actuator is recorded using the serial communication software.
- Extract the displacement data using the laser displacement measurement software and compare them for verification.
NOTE: Force-displacement data are recorded simultaneously using the serial communication software, allowing the force-displacement curve to be obtained on the laptop in real time. - Observe and record the deformation of the sample during compression using a digital microscope.
NOTE: The digital microscope and laser displacement meter are used for sample observation and displacement verification, respectively.
2. Measurement circuit
NOTE : Figure 3 shows the electrical equivalent circuit of the force sensor and the measurement circuit connections that convert and amplify pressure changes due to a static external force into a voltage. The circuit consists of a variable feedback resistor (RF) for gain control, a capacitor (CF) for low-frequency cutoff and noise removal, and an operational amplifier. Here, the resistance of the force sensor that changes with the magnitude of the externally applied force is RS, and the supply voltage for the sensor and the entire circuit is VS. Considering the inverting amplifier characteristics, VS is applied as a negative voltage to ensure the output is always positive.
- Connect a variable feedback resistor (RF) in parallel with a capacitor (CF) (for low-frequency cutoff and noise filtering) to form the feedback circuit.
- Connect the two terminals of the feedback circuit assembled above to the inverting input (−) and the output (VO) of the operational amplifier.
- Connect the two terminals of the pressure sensor's resistance (RS) to the inverting input (−) of the amplifier and to −VS.
- Connect the noninverting input (+) of the operational amplifier to ground.
- Connect the output (VO) of the operational amplifier to the input terminal A0 of the microcontroller board.
- Connect the VDD and VSS terminals of the amplifier to a power supply; apply 5 V to VDD and connect VSS to ground.
NOTE: The voltage settings for this amplifier follow the method suggested in the datasheet supplied with the force sensor to limit the output voltage to the range of 0-5 V. Figure 3 illustrates the force sensor's equivalent circuit and the inverting amplifier circuit. When a static external load is applied, the sensor resistance (RS) changes, and a sensor current (iS) flows according to the ratio of the supply voltage VS (the reference voltage for the sensor) to RS. This is equivalent to the output current (iO) defined by the ratio of the output voltage (VO) to the feedback resistor (RF). Applying Kirchhoff's current law at node a in Figure 3 yields Equation (1).
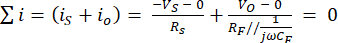 (1)
and VO is defined by Equation (2) under the very low-frequency external loading (ω ≅ 0).
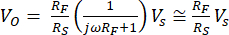 (2)
3. Sample preparation (PDMS) and loading
- Check the ASTM D575-91 standard specifications for the compression test sample.
NOTE: Figure 4A shows two 3D-printed cylindrical molds, which were prepared in a clean state prior to PDMS casting. One mold is designed as a cylindrical shape identical to the standard sample (diameter 28.6 mm ± 0.1 mm, height 12.5 mm ± 0.5 mm), and the other is a scaled-down version approximately one-third that size to fit the effective sensing area of the force sensor (diameter 9.53 mm). - Use PDMS as the test material, and mix the base polymer with the curing agent at a mass ratio of 10:1.
- After stirring thoroughly, degas the mixture at room temperature (25 °C) and 60 kPa (gauge) for 30 min using a vacuum desiccator to remove air bubbles.
- Inject 8 mL of the mixture into each of the two prepared 3D-printed molds using a disposable syringe to mold the samples.
- Cure all samples at room temperature for 24 h without any additional thermal treatment.
NOTE: Figure 4B shows the fabricated PDMS samples, and three samples of each size were prepared under identical conditions to enable comparison between the standard and scaled-down samples. Figure 4C shows the PDMS sample placed on the force sensor in the compression test setup. The sample was centered on the circular sensing region with its bottom surface fully contacting the active area of the force sensor. - Align the moving part perpendicular to the sensor and centered over the sample to apply a normal compressive load.
4. RF calibration
NOTE: RF is a key factor in determining the output voltage in the inverting amplifier circuit, so adjusting the RF value is critical for ensuring the accuracy and reliability of the MS.
- Attach the force sensor to the sample mounting area of the MTS (100 N load cell), and set the experimental load limit to 4.4 N.
- Using the MTS, perform compression tests under various RF conditions and record the force-time data from the force sensor at least three times.
- Compare the force-time data obtained from the force sensor with the MTS measurement data to calculate the error.
- Determine the RF value that yields the smallest error based on the calibration results.
NOTE: The maximum measurement range of the force sensor is 4.4 N. Loads exceeding this value cause output saturation, so care is required when setting the experimental conditions. Adjusting the RF value optimizes the gain of the circuit to match the MTS data, and this is a key step in ensuring the overall measurement accuracy of the system.
5. Vertical displacement validation
- For displacement validation, attach a microscope slide with an aluminum reflector to the top of the z-stage moving part.
- Turn on the laser displacement sensor.
- Verify that the signal of the laser sensor signal is stable.
NOTE: Check that the laser emission LED on the sensor is green. If it is orange, the aluminum reflective layer may not be reflecting properly, or the measurement range (<1 mm) may have been exceeded, so adjustments are required. - Use the motor controller to set the drive speed so that the moving part moves at a target speed of 1 µm/s. Apply the settings as follows:
- Launch the motor control software.
- Press Home Search to perform homing (calibration).
- To set the drive speed, go to Parameter/Mode < Parameter < Drive Speed, enter each value (5, 10, and 100), and then close the dialog box.
- To apply each speed setting, choose Speed Select and select each of 5, 10, and 100.
- To set the desired travel distance, enter a Preset value of 27,320 points and press the + (start) button.
NOTE: At a preset value of 27,320 points, as 1 point corresponds to 0.0366 µm, the moving part descends by a total of 1000 µm. The motor control software is used consistently for operating the motor controller during compression tests.
- While the moving part is moving along the z-axis, record the displacement data from the built-in linear actuator via the motor control software, and record the laser displacement data via the laser measurement software.
- Launch the laser displacement measurement software.
- For control settings, select Startup configuration setting < Read controller settings and press OK.
- Set the sampling time under Common settings < Sampling to 100 µs (Sampling cycle: 100), then save the settings and send them to the controller.
- To monitor the laser displacement, go to View Measurement Value < Start measurement value acquisition, and observe the displacement data.
NOTE: The sampling time is set to 10 ms (100 µs × 100 cycles) to acquire the laser displacement data with sufficient temporal resolution and to minimize signal noise for stable measurement.
- Compare the recorded displacement data from the two sources to evaluate the displacement error, and confirm that the displacement values match at each drive speed setting (5, 10, and 100). This ensures the reliability and repeatability of displacement measurements under the target speed conditions.
6. Mechanical property evaluation of the scaled-down sample
- Attach the force sensor to the top of the block using double-sided tape, then use the microcontroller board software's serial monitor to ensure that the initial load reads 0 and perform calibration if necessary.
- Open and launch the microcontroller board software.
- To configure the board connection and port, go to Select Other Board and Port < BOARDS < Search board, select Arduino Uno, and press OK.
- Enter the microcontroller board control code and click on Verify, then Upload.
- To check the load readings, go to Tools < Serial Monitor.
NOTE: The microcontroller board control code is provided in Supplementary File 1.
- Place the sample stably at the center of the force sensor's effective sensing area.
NOTE: If the sample is positioned off-center from the sensor's active area, the load will be applied asymmetrically, leading to large measurement errors. - Use the motor controller to perform homing (zero adjustment) and set the drive speed to the previously validated value.
- Drive the moving part of the z-stage axially (downward) to come into contact with and thereby apply a load to the sample.
- Measure the force transmitted to the sample in real time by the force sensor mounted underneath.
- Transmit the force-displacement data to the laptop via the inverting amplifier circuit connected to the microcontroller board, and record the force and displacement simultaneously using serial communication software.
- Launch the serial communication software.
- Connect to the microcontroller board software for recording force data: go to Connection < Options < Serial Port Options < Port, select the appropriate port, and press OK.
- Connect to the motor control software for recording displacement data: go to Connection < Options < Serial Port Options < Port, select the appropriate port, and press OK.
- To begin real-time data transmission, go to Connect < Connection < File Capture < Start.
- To stop and save the data, go to Connection < File Capture < Stop and Save.
- Convert the displacement data to strain by dividing the change in length (ΔL) by the initial length of the sample (L₀), i.e., strain = ΔL/L₀.
- Simultaneously, convert the recorded force data to stress by dividing the force (F) by the cross-sectional area (A) of the sample, i.e., stress = F/A.
- Figure 7 shows the stress-strain curves of the scaled-down PDMS samples. Using graph analysis software, calculate the slope in the initial small-strain region to determine the compressive modulus.
NOTE: To ensure consistency and reliability of the data, perform all compression tests at least three times under identical conditions. In this study, the compressive modulus of PDMS obtained from three repeated measurements was 1.39 MPa ± 3.7%.
Access restricted. Please log in or start a trial to view this content.
Results
This study successfully implemented a force sensor-based compression testing device, suitable for use in small-scale laboratories, that provides high measurement precision and reproducibility. This device was developed to overcome the high cost and large size of conventional commercial equipment and the inefficiencies in measuring small-strain deformations.
Figure 5 shows the optimization results for the RF value, which is the key factor determ...
Access restricted. Please log in or start a trial to view this content.
Discussion
This study presented a compression-based measurement method for evaluating the mechanical properties of polymer-based microstructures in the small-displacement regime. The proposed method combines a commercial Z-axis precision translation stage, a force sensor, a simple amplifier circuit, and a microcontroller board, and offers the advantage that it can be implemented in small laboratories and easily used by beginners.
A key factor in the performance of the equipment developed in this study is...
Access restricted. Please log in or start a trial to view this content.
Acknowledgements
This work was supported by a Korea Innovation Foundation (INNOPOLIS) grant funded by the Korean Government (Ministry of Science and ICT) (grant no. NTIS-2710084968), by the Commercialization Promotion Agency for R&D Outcomes (COMPA) funded by the Ministry of Science and ICT (grant no. RS-2024-00423871 to aid IP advancement and commercialization/industrialization of touch-off micro-needle manufacturing technology), and by the Regional Innovation System Education (RISE) program through the RISE Center, Gyeongsangnam-do, funded by the Ministry of Education (MOE) and the Gyeongsangnam-do Provincial Government, Republic of Korea (2025-RISE-16-008-0008).
Access restricted. Please log in or start a trial to view this content.
Materials
| Name | Company | Catalog Number | Comments |
|---|---|---|---|
| 3D printer | Stratasys | Objet30 Prime | Fabrication of two types of PDMS molds |
| Aluminium | Ningbo Favorld Commodity | Coating Silicone Oil Foil(Non-stick foil 01) | Formation of laser reflector for vertical displacement measurement |
| Breadboard | E-CALL | EIC-108J | For experimental circuit configuration |
| Capactior(CF) | Knowles / Cornell Dubilier (CDE) | CD15ED470GO3F | Noise filtering and stabilization of amplification circuit |
| Digital microscope | Hirox | KH-7700 | Observation of specimen shape and dimensional verification |
| Force sensor | Tekscan | FlexiForce A301-1 | Load measurement, resolution, and linearity are important |
| Graph analysis software | OriginLab | OriginPro 2024 | Graph analysis |
| Laptop | any | any | Core element for software control |
| Laser displacement measurement software | Keyence Corporation | LK-Navigator 1.52 | Vertical displacement measurement software |
| Laser displacement meter | Keyence Corporation | LK-G10 | Vertical displacement measurement equipment |
| Micro controller board | Arduino | A000067 | Main control unit for the entire system signal, including Arduino/STM-based boards |
| Microcontroller board software | Arduino | Arduino IDE 2.3.3 | Entire system signal control software |
| Microscope slide | LK LAB KOREA | M08-660-147 | Laser reflector for vertical displacement measurement |
| Motor control software | NOVA Electronics | MR220A 1.0.3 | Linear actuator control software |
| Motor controller | Sciencetown | STM-1-USB | Z-stage linear actuator driving control |
| MTS | Lloyd Instruments | 01/2962 | Commercial tensile/compression tester, reference equipment for measurement results |
| Operational amplifier | Microchip Technology | OPA404KP | Amplification of force sensor signal, key circuit component |
| PDMS | Dow Corning | 4019862 | Material for sample fabrication |
| Serial communication software | Roger Meier | CoolTerm 2.3.0 | Serial communication of force–displacement data |
| Vacuum desiccator | iNexus | IN-VS | Used for bubble removal during PDMS fabrication |
| Variable feedback resistor(RF) | BI Technologies / TT Electronics | P160KN-0QD15B10K | Operational amplifier gain adjustment, key for sensor calibration |
| Z-stage | Sciencetown | SMX-8060-X | Driving unit for displacement application and compression testing, core for precise vertical control |
References
- Iannacci, J. Reliability of MEMS: A perspective on failure mechanisms, improvement solutions and best practices at development level. Displays. 37, 62-71 (2015).
- Yamazu, T. Mechanical property measurement of micro/nanoscale materials for MEMS: A review. IEEJ Trans Electr Electron Eng. 18, 308-324 (2022).
- Lodh, A., Keller, C., Castelluccio, G. M. Fabrication and mechanical testing of mesoscale specimens. JOM. 75, 2473-2479 (2023).
- Haque, M. A., Saif, M. T. A. A review of MEMS-based microscale and nanoscale tensile and bending testing. Exp Mech. 43, 248-255 (2003).
- Pantano, M. F., Espinosa, H. D., Pagnotta, L. Mechanical characterization of materials at small length scales. J Mech Sci Technol. 26, 545-561 (2012).
- Zhang, Y., et al. Scalable and high-throughput production of an injectable PRP/cell-laden microcarrier/hydrogel composite system for hair follicle tissue engineering. J Nanobiotechnol. 20 (1), 465(2022).
- Rzepiejewska-Małyska, K. A., et al. In situ mechanical observations during nanoindentation inside a high-resolution scanning electron microscope. J Mater Res. 23 (7), 1973-1979 (2008).
- Cruz, D. J., Duarte, P., Alves, L. M., Martins, P. A. F. A miniaturized device coupled with digital image correlation for mechanical testing. Micromachines. 13 (11), 2027(2027).
- Lamba, M., Chaudhary, H., Singh, K. Analytical study of MEMS/NEMS force sensor for microbotics applications. IOP Conf Ser Mater Sci Eng. 594, 012021(2019).
- Cruz, D. J., Duarte, P., Alves, L. M., Martins, P. A. F. A miniaturized device coupled with digital image correlation for mechanical testing. Micromachines. 13 (11), 2027(2022).
- Liu, M., Sun, J., Sun, Y., Bock, C., Chen, Q. Thickness-dependent mechanical properties of polydimethylsiloxane membranes. J Micromech Microeng. 19 (3), 035028(2009).
- Liu, M., Sun, J., Chen, Q. Influences of heating temperature on mechanical properties of polydimethylsiloxane. Sens Actuators A Phys. 151, 42-45 (2009).
- ASTM International. ASTM D575-91, Standard Test Methods for Rubber Properties in Compression. , ASTM International. West Conshohocken, PA. (2018).
- Zhang, S., Ge, C., Liu, R. Mechanical characterization of the stress-strain behavior of the polydimethylsiloxane (PDMS) substrate of wearable strain sensors under uniaxial loading conditions. Sens Actuators A Phys. 341, 113580(2022).
- Pakawan, T., et al. Compressive behaviors of micropillar sheets made of PDMS material using the finite element method. Eng J. 24, 73-84 (2020).
- Johnston, I. D., McCluskey, D. K., Tan, C. K. L., Tracey, M. C. Mechanical characterization of bulk Sylgard 184 for microfluidics and microengineering. J Micromech Microeng. 24, 035017(2014).
- Ruybalid, A., van der Sluis, O., Geers, M., et al. An in-situ, micro-mechanical setup with accurate, tri-axial, piezoelectric force sensing and positioning. Exp Mech. 60, 713-725 (2020).
- Mehdizadeh, E., Guo, X., Pourkamali, S., Hajjam, A., Rahafrooz, A. Nano-precision force and displacement measurements using MEMS resonant structures. Proc IEEE Sens. 1, 1-4 (2013).
- Liu, S., et al. Small-strain folding of semi-rigid elastomer derives high-performance 3D-printable soft origami actuators. Chem Eng J. 489, 151462(2024).
- Singh, A. V., et al. Bioinspired soft machines: Engineering nature's grace into future innovations. J Funct Biomater. 16, 158(2025).
- Nandy, K., Collinson, D. W., Scheftic, C. M., Brinson, L. C. Open-source micro-tensile testers via additive manufacturing for the mechanical characterization of thin films and papers. PLoS One. 13 (5), e0197999(2018).
- Gianola, D. S., Hintsala, E. D., Uchic, M. D., Wheeler, J. M. Advances and opportunities in high-throughput small-scale mechanical testing. Curr Opin Solid State Mater Sci. 27, 101090(2023).
- Hartansky, R., et al. Towards a MEMS force sensor via the electromagnetic principle. Sensors. 23 (3), 1241(2023).
- Navindaran, K., Kang, J. S., Moon, K. Techniques for characterizing mechanical properties of soft tissues. J Mech Behav Biomed Mater. 138, 105575(2023).
- Chavan, R., Kamble, N., Kuthe, C., Sarnobat, S. On mechanical behavior and characterization of soft tissues. Biomed Eng Comput Biol. 15, 11795972241294115(2024).
- Babapour, F., Faraji Rad, Z., Ganji, F. Mechanics of dissolving microneedles insertion into the skin: Finite element and experimental analyses. J Appl Polym Sci. 141, e55973(2024).
Access restricted. Please log in or start a trial to view this content.
Reprints and Permissions
